

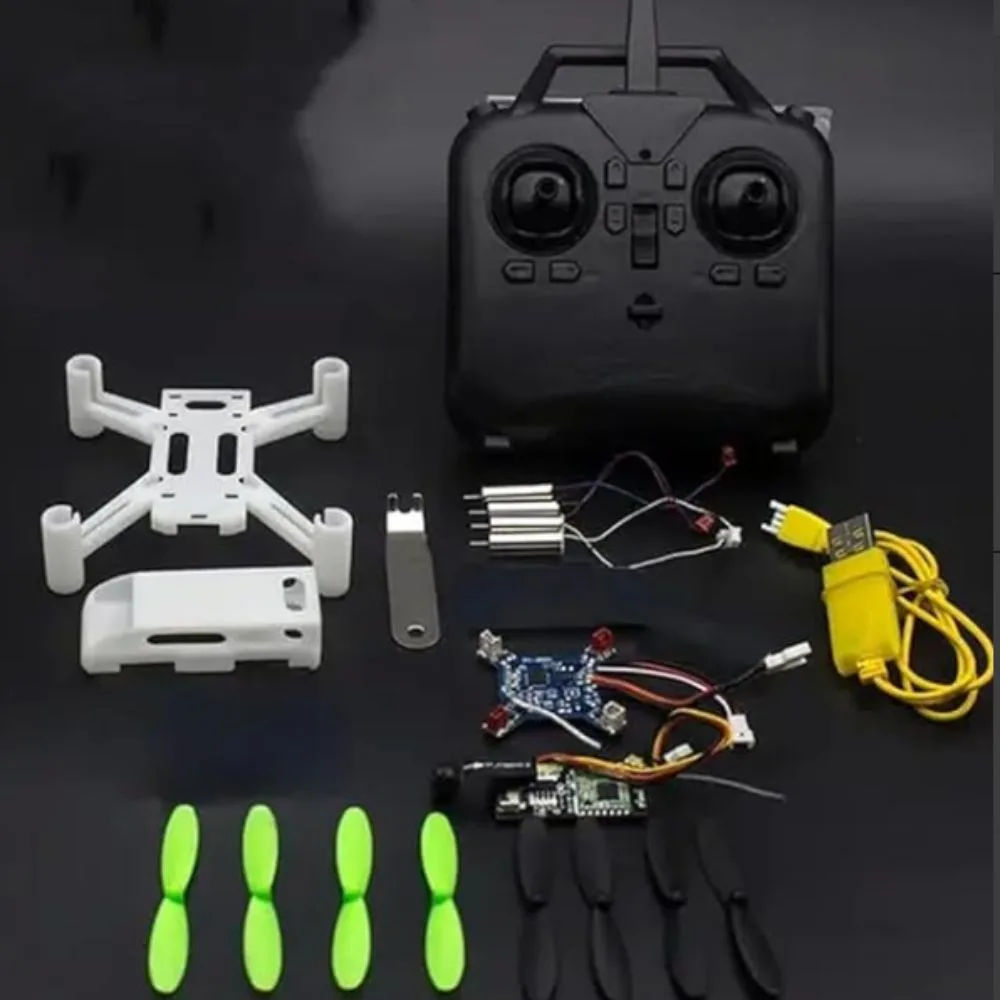
This type of kit typically includes (or allows you to supply) parts to build a quadcopter (4-rotor drone) that can hover stably (i.e. hold altitude) and often includes a camera (for video, FPV, or pictures). The frame of the quadcopter may be 3D-printable (you print the structural parts yourself using PLA, PETG, or other filament), which gives flexibility in customizing shape, weight, and mounting points.
The educational aspect often means it’s modular, transparent, documented, and suitable for learning electronics, control theory, programming, and mechanical design.
Key Features to Look For in a Good Kit
When selecting or designing such a kit, consider these features:
| Feature | Why It Matters |
|---|---|
| Stabilization / Flight Controller with Sensors | To achieve hovering, the drone needs a controller board (with accelerometer, gyroscope, possibly barometer) and firmware for stabilization (e.g. Betaflight, Ardupilot, etc.). |
| Camera or FPV (First-Person View) System | For educational video feedback, autonomy, or capturing images. |
| Modular / Replaceable Parts | If something breaks, you want to swap motors, arms, etc. easily. |
| Lightweight but Rigid Frame | Using 3D-printed materials (like PLA, PETG, carbon-fiber reinforced filament) gives customizability, but must be stiff and durable. |
| ESCs (Electronic Speed Controllers) | These drive the motors; their current rating must match the motors. |
| Motors & Propellers | Brushless motors (often 1800 – 5000 kV depending on size) and matched propellers. |
| Battery & Power System | Lithium Polymer (LiPo) battery suited to weight and runtime. |
| Telemetry / Communication / Remote Control | Radio link, receiver, possibly telemetry for battery status, etc. |
| Documentation / Firmware Support | Good kits come with guides, wiring diagrams, and firmware for stability control. |
| 3D Model Files / CAD | So you can tailor the frame or parts (e.g. STL or STEP files). |
Sample Kits & Building Blocks
Below are some sample kits or components (or similar ones) you can consider. (Note: I did not find an exact “3D print hovering quadcopter with camera kit” in the search results, but these are representative or related.)
-
DIY Mini Drone Kit — A science kit that lets you build a small quadcopter. It doesn’t necessarily include full stabilization, but is good for learning basics of motors, lift, wiring, etc.
-
DIY / hobbyist parts for 3D-printed micro drones — many hobbyists 3D-print tiny frames and pair them with off-the-shelf electronics (motors, ESCs, flight controllers) to make small quadcopters.
-
SkyBot 3D Printed Drone (education / kit) — a drone whose frame is 3D-printed, designed for educational use.
If you’d like, I can search for kits that ship to Rwanda (or your region) and show you direct purchase links.
Building Your Own Educational 3D-Printed Quadcopter: Steps & Tips
Below is a rough roadmap and tips to build such a drone from scratch or from modular parts.
1. Design or Download Frame / 3D Model
-
Use existing open-source drone frame designs (STL files) as a starting point.
-
Optimize the frame for weight vs strength: arms should be stiff, minimal flex.
-
Include mounting holes for motors, camera, flight controller, battery, etc.
-
Use strong filaments like PETG, ABS, or carbon-fiber reinforced PLA for key stress parts.
2. Choose Motors and Propellers
-
Pick motors sized to your payload. A common rule is each motor should provide ~2× the thrust of the total weight (with margin).
-
Choose propellers matched to motor size (e.g. 5″, 6″, etc.).
-
Use motors with specifications of KV (rpm per volt) appropriate to your battery voltage.
3. Electronic Speed Controllers (ESCs)
-
Choose ESCs whose current rating is comfortably above the motor’s maximum current draw.
-
Use ESCs that support fast response (for stability) and ideally ones compatible with your flight controller (BLHeli, etc.).
4. Flight Controller & Stabilization Firmware
-
Use a flight controller board that has IMU sensors (gyro + accelerometer). Options: F4, F7, etc.
-
Use open firmware: Betaflight, Ardupilot, or similar, so the drone can auto-level, hover, and stabilize.
-
Tuning PID settings is essential to stable hovering.
5. Camera / Video System
-
For FPV (first-person view), include a small camera + video transmitter (VTX).
-
Alternatively, mount a lightweight action camera (e.g. 1080p) if weight allows.
6. Battery & Power
-
Use LiPo battery appropriate for weight and desired flight time.
-
Provide power distribution board or wires to route current to ESCs.
-
Ensure voltage regulators if needed for your electronics.
7. Assembly & Wiring
-
Mount motors to frame arms, wire ESCs to motors and to the power distribution.
-
Mount flight controller centrally; keep wiring short and tidy.
-
Mount camera in front, ensure vibration isolation if needed.
-
Secure battery with straps.
8. Configuration & Testing
-
Connect flight controller to PC, configure firmware, calibrate sensors (accelerometer, gyro, ESC throttle range).
-
Start with hover tests at low throttle.
-
Adjust PID gains to reduce oscillation and improve stability.
-
Monitor motor temperatures, battery voltage, vibration.
Tips & Best Practices for Hovering & Stability
-
Balance the propellers and motors to reduce vibration which can lead to instability.
-
Minimize wiring length and keep wires symmetric to reduce electrical noise and imbalances.
-
Add soft mounts or damping (e.g. rubber pads) under flight controller to isolate from vibration.
-
Tune PID carefully — too aggressive can oscillate, too weak will drift.
-
Use telemetry — monitor battery voltage in flight to avoid mid-air power loss.
-
Always do low-altitude tests first, so if something fails, damage is minimal.
-
Keep spare parts — props, motors, ESCs, screws — especially for educational use.
-
Design for modularity — make arms removable if crashes happen.
-
Use small protective guards to prevent damaging propellers or injuring bystanders.
-
Consider automatic “level hold” modes for beginners to get stable hover without full manual control.


There are no reviews yet.