

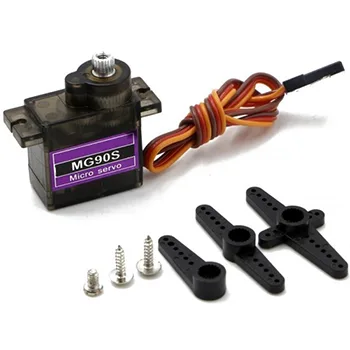
MG90S Servo is small and lightweight but boasts a high output power for its size. This is largely due to its metal gear and bearing. This makes it much more durable than other types of small servo that feature plastic gears and bearings.
Specifications
- Small and compact yet high power output.
- Metal gears for strength and durability.
- Suitable for RC models and Robotics projects.
- 180 degrees of rotation, 90 in each direction.
- Operating Voltage of 4.8V – 6V.
Features:
- MG90S Datasheet
- Compatible with Arduino Servo library
- Metal gears
- Operating Voltage: 4.8 – 6VDC
- Speed at 4.80V (no load): 0.1 s/60°
- Torque at 4.80V: 1.8 kg.cm (~0.1765 N.m)
- Range of motion: 0° to 180°
- Parameters for 4.8 V:
- Torque: 1.8 kg.cm (0.2 Nm)
- Speed: 0.1 s/60°.
- Parameters for 6.0 V:
- Torque: 2.2 kg.cm (0.23 Nm)
- Speed: 0.08 s/60°
- Wiring:
- Brown = GND
- RED = 5V
- Orange = Signal

MG90S Wiring Description
| Wire Number | Wire Colour | Description |
| 1 | Brown | Ground wire connected to the ground of system |
| 2 | Red | Powers the motor typically +5V is used |
| 3 | Orange | PWM signal is given in through this wire to drive the motor |
Servo Motor Micro MG90S Test Program
/*
  Exercise Servo motor
  Use a potentiometer on pin A0 to command a servo attached to pin 9 to move to
  a specific position.  The Servo MIN_VALUE and MAX_VALUE can be adjusted to
  avoid hitting the servo stops
  Uses built-in Servo.h library
*/
#include "Servo.h"
#define SERVO_PIN 9   // Can use any PWM pin
#define POT_PIN A0    // Can use any analog pin
#define MIN_VALUE 0   // Minimum Servo position
#define MAX_VALUE 180 // Maximum Servo position

Servo servo;          // creates servo object used to control the servo motor
int value_pot = 0;    // Current value of the potentiometer
int value_servo = 0;  // Current servo position
int value_servo_old = 0; // Used to hold old servo value to look for change.
//===============================================================================
//  Initialization
//===============================================================================
void setup()
{
  servo.attach(SERVO_PIN); // assigns PWM pin to the servo object
  Serial.begin (9600);     // Set Serial Monitor window comm speed
}
//===============================================================================
//  Main
//===============================================================================
void loop()
{
  value_pot = analogRead(POT_PIN); // Reads value of the potentiometer. Return value = 0 to 1023
  value_servo = map(value_pot, 0, 1023, MIN_VALUE, MAX_VALUE); // remap pot value to servo value
  if (value_servo != value_servo_old) {   // Only do something if there's a change in the servo position
    servo.write(value_servo);        // Update servo position
    Serial.print("Pot Value: ");  // Update Serial Monitor window with what's going on
    Serial.print(value_pot);
    Serial.print("tServo Value: ");
    Serial.println(value_servo);
    value_servo_old = value_servo;
    delay(25); // give servo time to move
  }
}
Packing list:
- 1x MG90S Micro Servo Motor 9g (180 degree)

There are no reviews yet.