


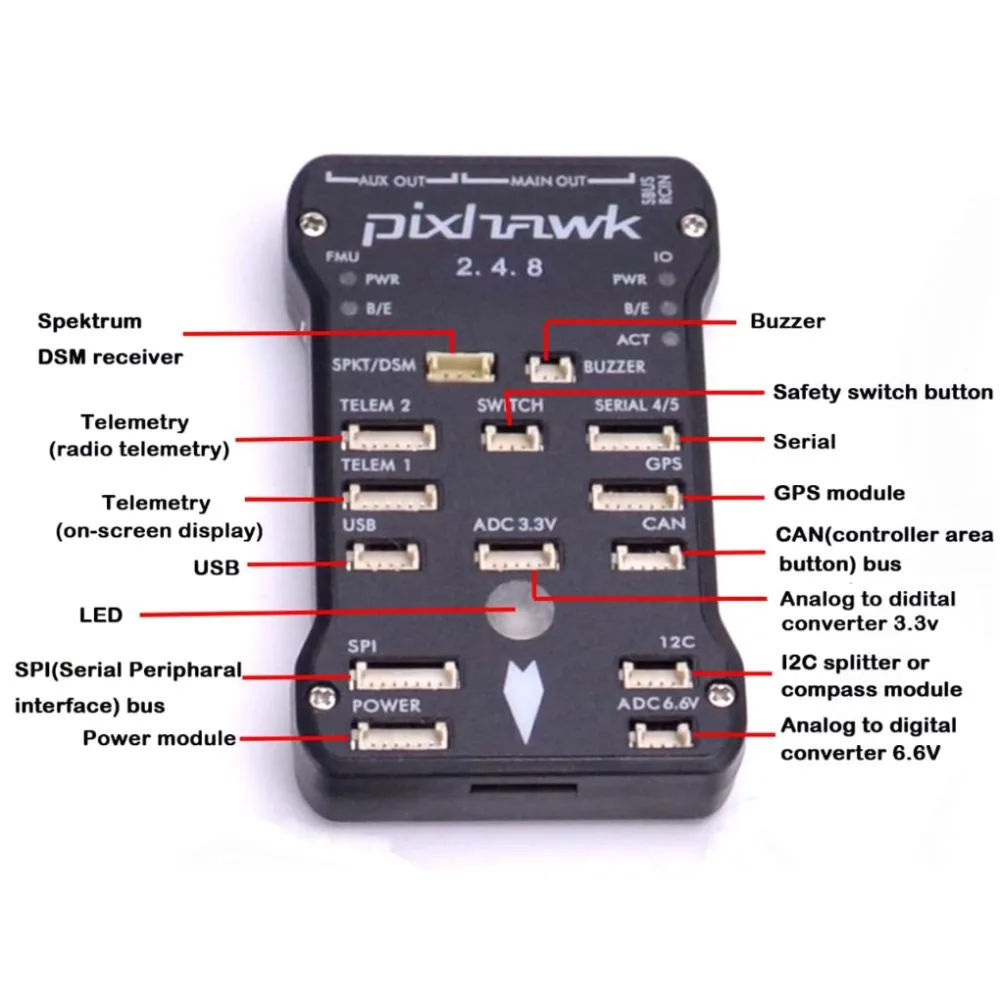

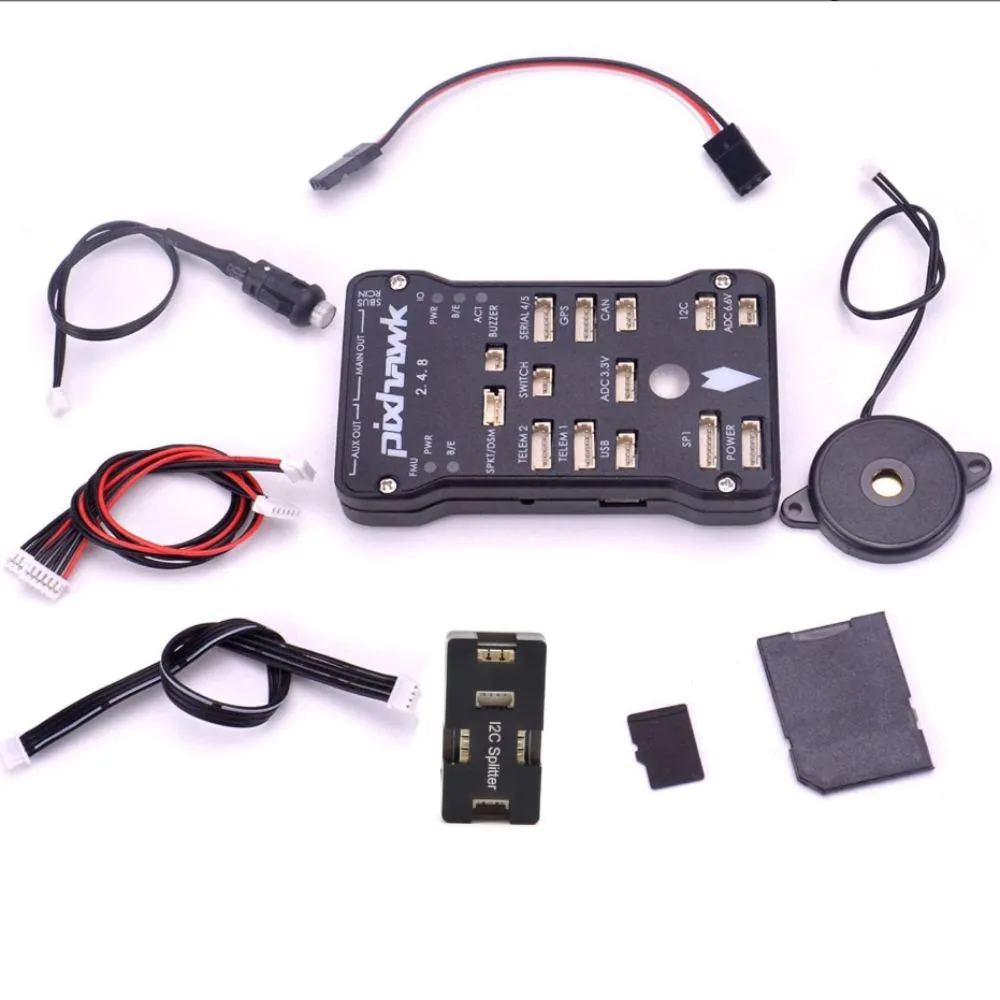
The Pixhawk PX4 PIX 2.4.8 Flight Controller is a powerful 32-bit open-source autopilot system designed for controlling drones, quadcopters, fixed-wing airplanes, RC cars, and boats. It is based on the PX4 / ArduPilot ecosystem and provides advanced flight stabilization, autonomous navigation, and mission planning.
This controller includes an 8GB SD card for flight data logging, PPM input support, and an I2C splitter to connect multiple sensors. It is widely used by hobbyists, researchers, and engineers for building professional UAV systems.
Features
-
32-bit ARM processor flight controller
-
Compatible with PX4 and ArduPilot firmware
-
8GB Micro-SD card for flight data logging
-
Multiple interfaces: PPM, PWM, I2C, SPI, UART
-
Supports GPS, telemetry radio, and external sensors
-
Advanced autonomous flight capabilities
-
Built-in IMU, gyroscope, and accelerometer
-
Supports failsafe and safety features
Specifications
| Parameter | Specification |
|---|---|
| Model | Pixhawk PX4 2.4.8 |
| Processor | 32-bit ARM Cortex |
| Firmware Support | PX4 / ArduPilot |
| Memory | Micro-SD card (8GB included) |
| Input Signals | PPM / SBUS / PWM |
| Communication Ports | UART, I2C, SPI, CAN |
| Sensors | Gyroscope, Accelerometer, Magnetometer, Barometer |
| Voltage Input | 4.8V – 5.4V |
| Applications | UAV, RC vehicles, robotics |
Main Components
1. Main Processor
The 32-bit processor runs the flight control algorithms and autopilot functions.
2. IMU Sensors
Includes:
-
Gyroscope
-
Accelerometer
-
Magnetometer
-
Barometer
These sensors allow the controller to stabilize and control flight.
3. I2C Splitter
Allows connection of multiple external modules such as:
-
GPS
-
Compass
-
Airspeed sensor
-
External sensors
4. PPM / PWM Inputs
Used to receive commands from the RC receiver or transmitter.
5. Micro-SD Card
Stores flight logs and telemetry data for analysis.
Supported Devices
The Pixhawk controller can connect to many UAV components:
-
GPS module
-
Telemetry radio
-
Power module
-
RC receiver
-
ESC and motors
-
Gimbals and cameras
Applications
The Pixhawk PX4 2.4.8 is widely used in:
-
FPV quadcopters
-
Fixed-wing drones
-
Autonomous boats
-
Robotic vehicles
-
UAV research and development
-
Drone education and training
Advantages
Open-source flight control platform
Highly customizable firmware
Supports many sensors and peripherals
Reliable autonomous flight system
Large developer and user community
Usage Tips
-
Use Mission Planner or QGroundControl software for configuration
-
Calibrate sensors before first flight
-
Ensure proper power module connection
-
Secure GPS and compass away from interference
-
Update firmware to latest version
Maintenance
-
Keep the controller protected from dust and moisture
-
Check cable connections regularly
-
Update firmware when new versions are available
-
Store flight logs for troubleshooting and analysis
There are no reviews yet.