


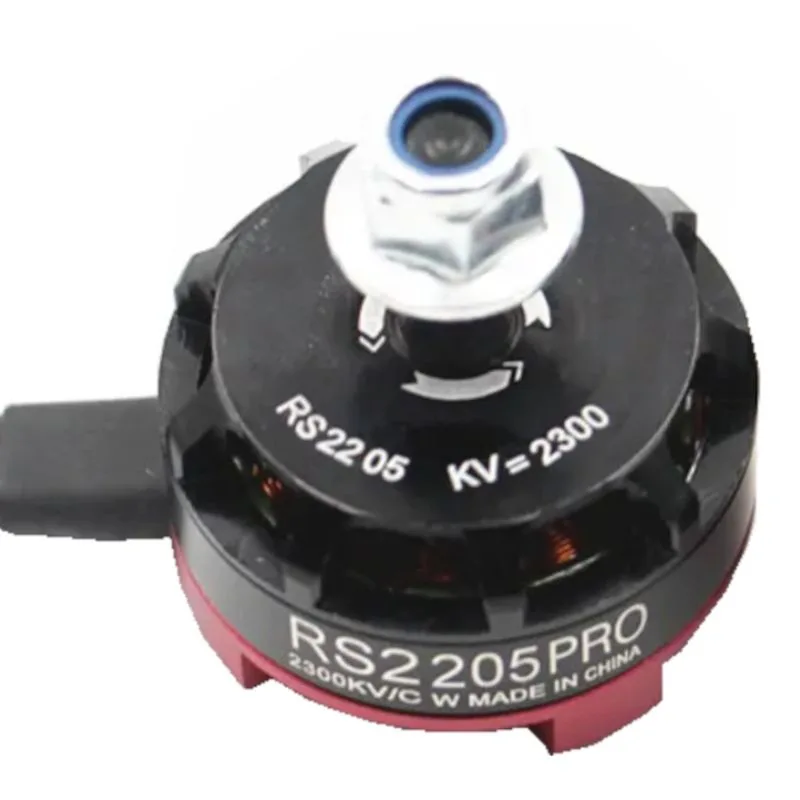
The RS2205 2300KV (CCW) is a high-performance brushless outrunner motor designed for FPV racing drones, multirotors, and aerial robotics.
It is part of the Emax “Red Bottom” RS2205 series, known for its strong thrust, durability, and efficiency.
The “CCW” version refers to the thread direction on the motor shaft — designed to prevent the propeller nut from loosening when the motor spins counter-clockwise.
Key Features
| Feature | Description |
|---|---|
| Type | Outrunner Brushless DC Motor |
| KV Rating | 2300 KV (≈ 2300 RPM per volt applied) |
| Rotation Direction | CCW (Counter-Clockwise) |
| Thread Type | Reverse (CCW) thread on shaft – prevents prop nuts from loosening |
| Shaft Diameter | 5 mm |
| Motor Dimensions | 27.9 mm diameter × 31 mm height |
| Weight | ≈ 30 g (without wires) |
| Stator Configuration | 12N14P (12 slots, 14 poles) |
| Bearing Type | High-speed ball bearings for reduced friction |
| Propeller Mount | M5 reverse-thread lock nut |
| Construction | CNC-machined aluminum bell, N52 neodymium magnets |
| Cooling System | Airflow design with vented bell housing for heat dissipation |
| ESC Compatibility | 20A–30A BLHeli / SimonK / DShot-compatible ESCs |
| Power Connector Wires | 3 × 20 AWG silicone wires (≈70 mm length) |
Technical Specifications
| Parameter | Typical Value |
|---|---|
| Model | RS2205-2300KV (CCW) |
| KV Rating | 2300 KV |
| Input Voltage | 2S – 4S LiPo (7.4 V – 14.8 V) |
| Max Continuous Current | ~28 A |
| Max Power Output | ~380 W |
| Internal Resistance (Rm) | ~0.08 Ω |
| Idle Current (Io) | ~0.8 A (10 V) |
| Recommended Propellers | 5×4.5″, 5×3″, 6×4.5″ |
| Recommended ESC | 20–30 A Brushless ESC |
| Mounting Hole Pattern | 16 mm × 19 mm, M3 screws |
| Motor Poles | 14 |
| Efficiency | ~80–85% at mid-load |
Typical Thrust Performance (Tested on 4S LiPo)
| Propeller | Throttle | Thrust (g) | Current (A) | Power (W) |
|---|---|---|---|---|
| 5045 | 100% | ~980 g | ~26 A | ~390 W |
| 5040 | 100% | ~900 g | ~24 A | ~355 W |
| 6030 | 100% | ~1100 g | ~30 A | ~450 W |
(Values may vary depending on propeller brand and air temperature.)
Tips for Proper Use
-
Match direction properly:
-
CCW motors are mounted on arms that spin counter-clockwise.
-
Use CW-threaded nuts on CCW motors to prevent loosening.
-
-
Balance your propellers to reduce vibrations and protect the bearings.
-
Power matching: Use quality 3S or 4S LiPo batteries and 20–30 A ESCs (BLHeli-S or DShot recommended).
-
Cooling: Maintain good airflow — avoid covering the motor bell to prevent overheating.
-
Use proper screws: M3 × 5–6 mm screws are safe; avoid long screws that could damage the windings.
-
Use thread-locker (Loctite) on prop nuts to prevent vibration loosening.
-
ESC calibration: Calibrate your ESCs for smooth throttle control before flight.
-
Avoid oversize props — large props draw too much current and may overheat the motor.
-
Test current draw on the bench before flying your drone setup.
Applications
-
FPV Racing Drones (210–250 mm frames)
-
DIY Educational Quadcopter / Hexacopter Projects
-
RC Planes or Hovercrafts
-
Robotics projects needing high RPM and torque in small form factor
-
3D printed hover drones or air-cushion vehicles
CW vs CCW Difference (Summary)
| Parameter | CW Motor | CCW Motor |
|---|---|---|
| Thread Direction | Clockwise | Counter-clockwise |
| Typical Position | Front-right & rear-left arms | Front-left & rear-right arms |
| Prop Nut Tightens | Clockwise | Counter-clockwise |
| Purpose | Prevents propeller loosening during rotation | Same (opposite direction) |
Typical Drone Setup (Example)
| Component | Specification |
|---|---|
| Motor | 4 × RS2205 2300KV (2 CW + 2 CCW) |
| ESC | 4 × 30A BLHeli_S or BLHeli_32 |
| Flight Controller | F4 or F7 FC (Betaflight-compatible) |
| Battery | 3S or 4S LiPo, 1300–1500 mAh, 75C+ |
| Frame | 210–250 mm racing frame |
| Props | 5×4.5 or 5×4.3 tri-blade |
| Receiver | 2.4 GHz RC system |
| Total Thrust | Up to ~4 kg (1 kg per motor on 4S) |
Drone Motor robotic robot



There are no reviews yet.